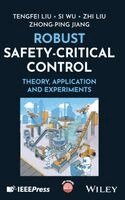
Robust Safety-Critical Control
1 597 krhos Bokus · exkl. frakt
482 kr skillnad mellan billigaste och dyraste butik i lager
Dubbelkollat idag
Jämför 2 butiker
- Bokus, 1 597 kr, frakt enligt butiken. Till butik (öppnas i ny flik)
I lagerFrakt: se butikenDubbelkollad 16:51
1 597 kr
Lägst
- Akademibokhandeln, 2 079 kr, frakt enligt butiken. Till butik (öppnas i ny flik)
I lagerFrakt: se butikenDubbelkollad 16:53
2 079 kr
Priser från butikernas flöden kan ha ändrats: det är priset hos butiken som gäller, så kontrollera det innan du handlar.
Prishistorik
Köp nu eller vänta?
Pris idag
1 597 kr
- Lägst
- 1 567 kr
- Snitt
- 1 635 kr
- Högst
- 2 039 kr
| 2026-10-07 | 2 039 kr · Lägst hos Akademibokhandeln |
|---|---|
| 2026-10-08 | 1 567 kr · Lägst hos Bokus |
| 2026-10-10 | 1 597 kr · Lägst hos Bokus |
Om produkten
Robust Safety-Critical Control
Läs merLäs mindre
Practical tools and techniques to achieve objectives in safety-critical control This book offers a systematic framework for the safety-critical control of nonlinear uncertain systems, with key contributions such as the development of novel small-gain synthesis and feasible-set reshaping techniques to address interactions between the nominal controlled system and dynamic uncertainties. Incorporating recent advancements in the field, this book showcases the strengths of the proposed framework by tackling key theoretical challenges in safety-critical control across multiple benchmark systems. It further highlights the real-world impact of the developed methods and algorithms through practical applications involving vehicles, quadrotors, and robotic manipulators. All results are supported by laboratory experiments with clear explanations. Written by a team of highly qualified authors, Robust Safety-Critical Control includes: Insights into the challenges of designing controllers that maintain safety while achieving??desired objectives, in the presence of uncertainties, nonlinear dynamics, and??multiple constraintsA mathematical foundation for robust safety-critical control, presented in the appendices covering quadratic optimization, Lyapunov stability theory, input-to-state stability, and the nonlinear small-gain theoremChapter-by-chapter problem formulations and detailed, rigorous developments of the theory and methods, guiding the reader through the process of addressing the fundamental challengesComprehensive system setups for safety-critical control simulations and experimentsReady-to-use code implementations for key algorithms, including the feasible-reshaping technique and small-gain control methodsRobust Safety-Critical Control is an excellent reference for researchers and graduate students in systems and control, robotics, transportation, and AI seeking to expand their knowledge bases. The text is also highly valuable for engineers and practitioners in control engineering, civil and urban engineering, robotics, and manufacturing.